

HSM ARIES / THE PEOPLE BEHIND THE ROVER
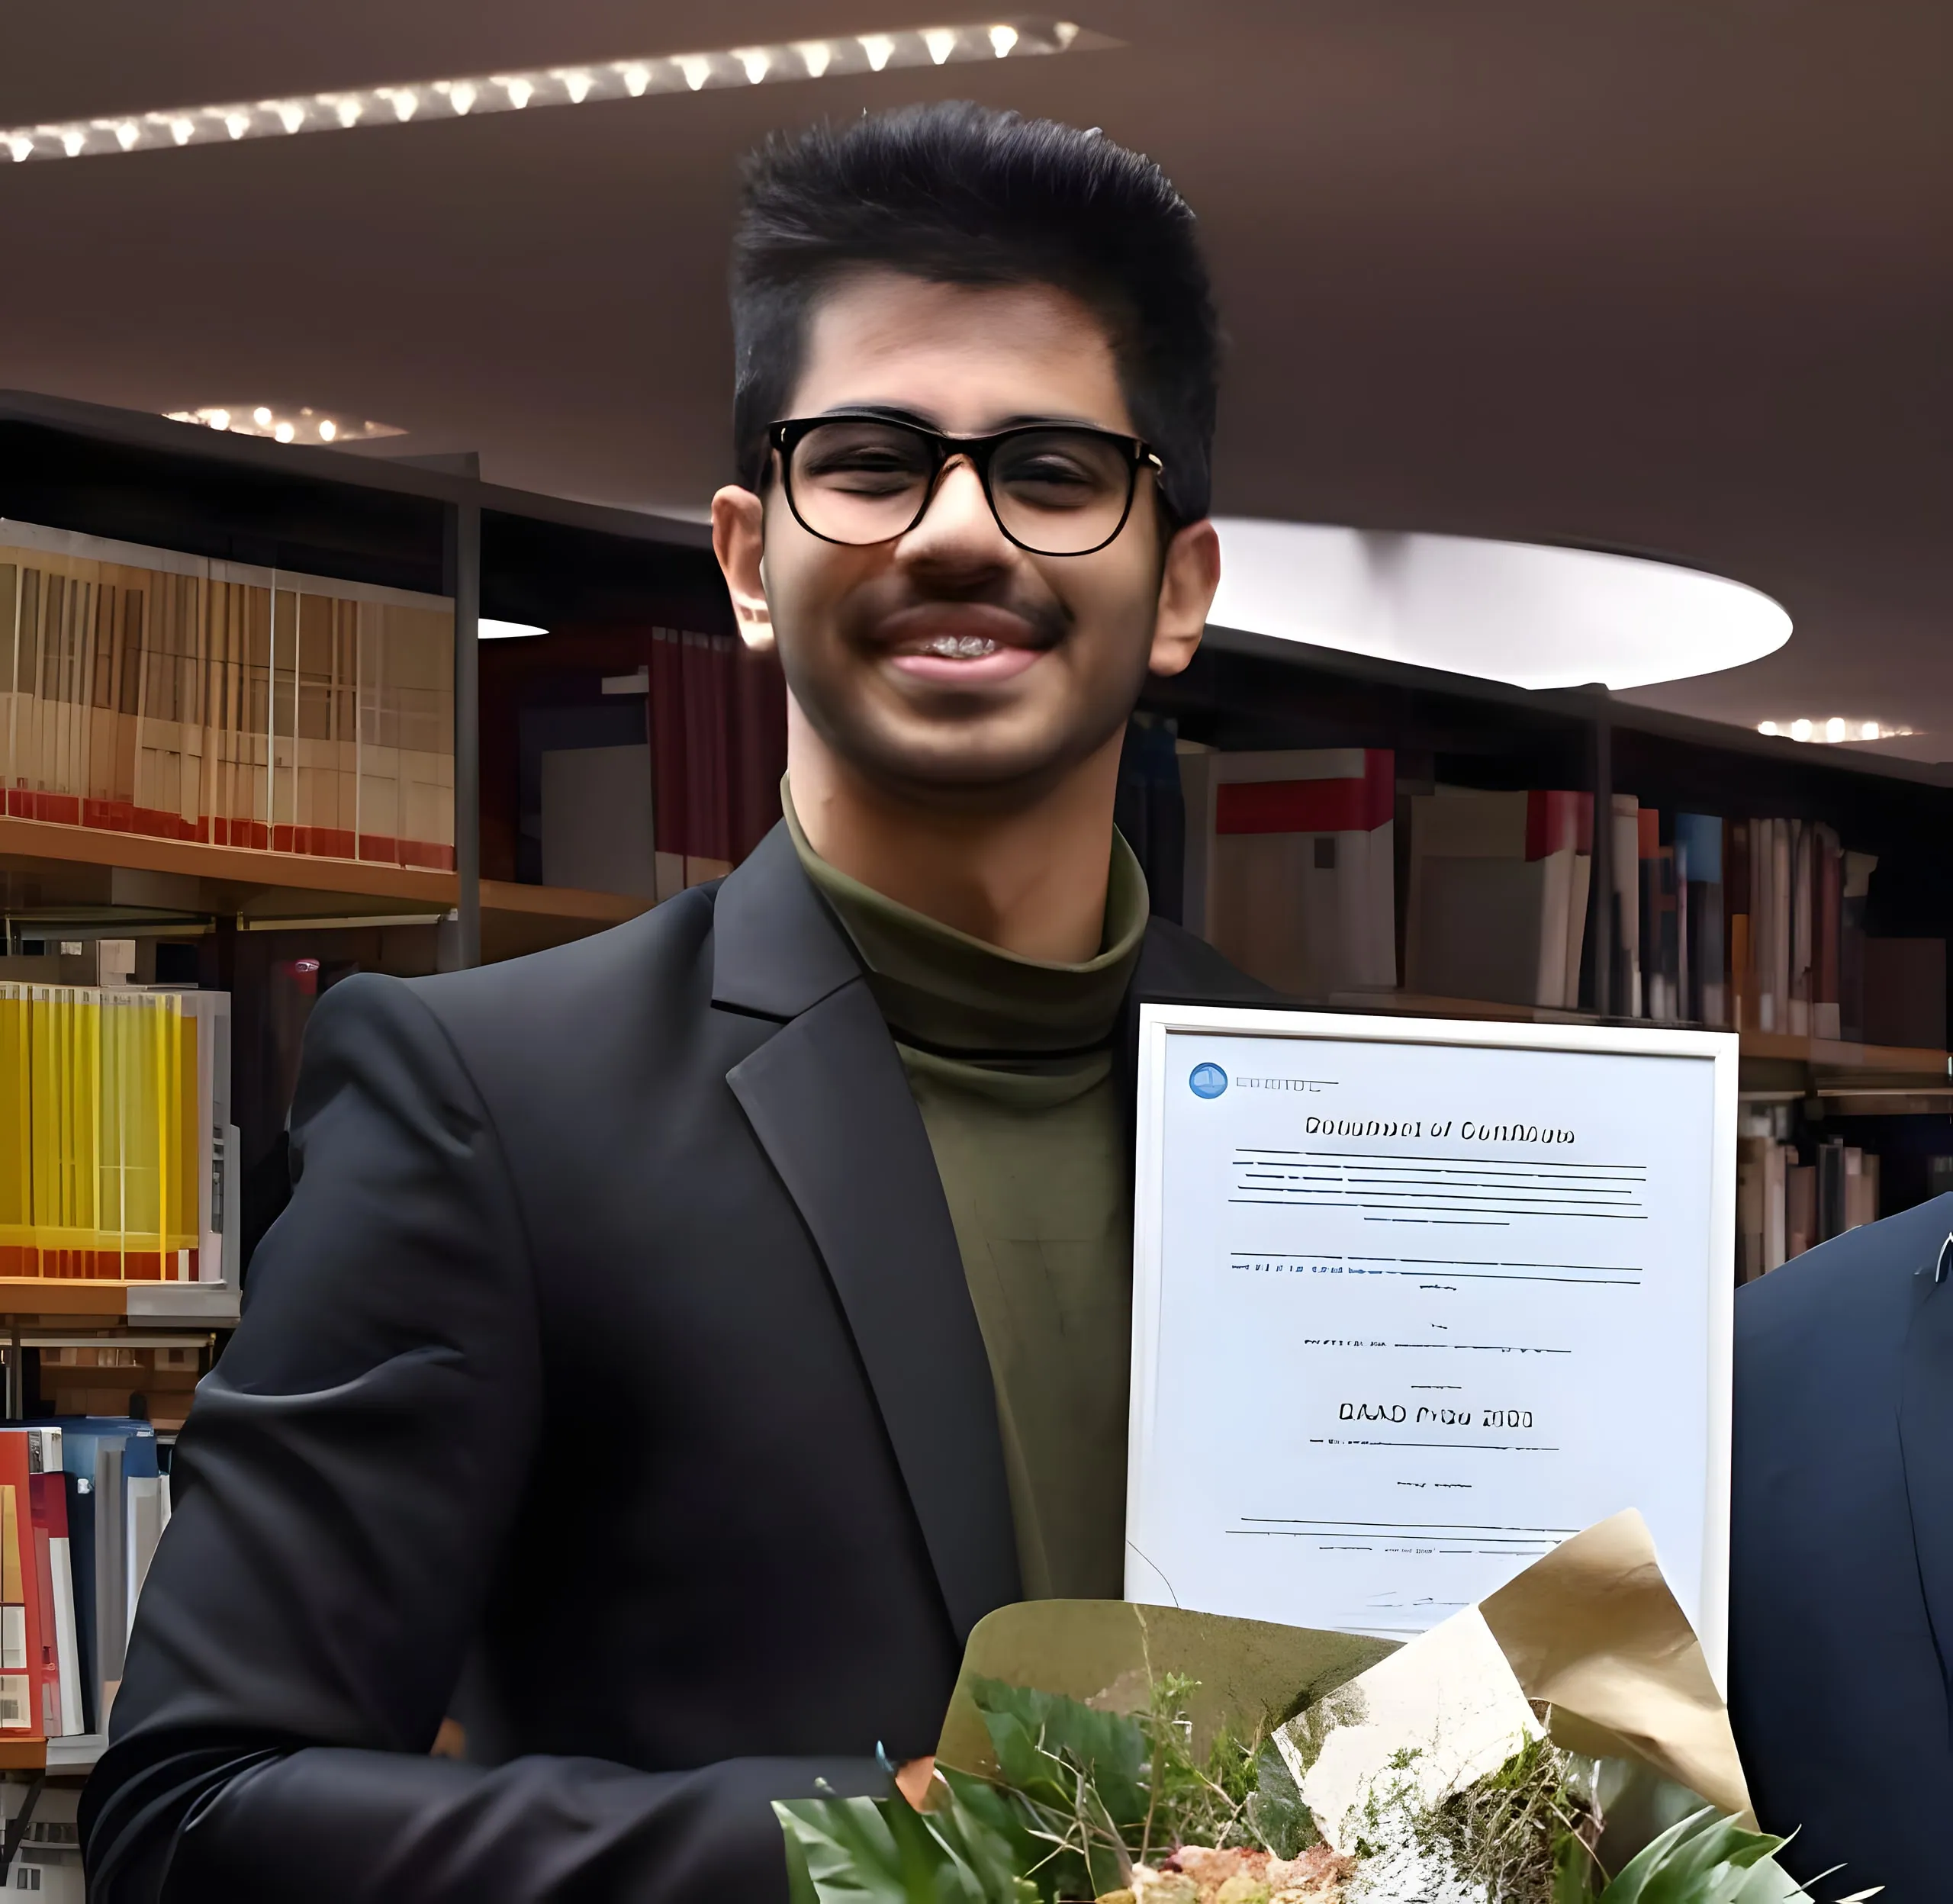
Swaraj Tendulkar
University Mentor
- Advisors & Mentors
On the team
Swaraj helped establish HSM Aries and mentors the team across architecture, integration and mission preparation. His role connects the many technical decisions made by individual departments with the practical question of how a complete robot behaves outside the lab.
His own research addresses outdoor mobile robots, environment perception and interactions with pedestrians. It includes published work on vehicle-to-everything perception and occupancy analysis, and a newer preprint organising navigation into global, static and dynamic map layers. He is also a coauthor of the LEAP-One design preprint. That research gives his mentoring a concrete foundation in the sensing and navigation challenges faced by real mobile robots.
Selected research & projects
LEAP-One: A Mars Rover Designed for Remote Mars Analogue Scientific Exploration and Sampling Missions — 2026 preprint; rover design, scientific sampling and remote operation.
V2X based Vehicle Environment Perception and Occupancy Analysis for Dynamic Pedestrian Behaviour — European Control Conference, 2024. S. Tendulkar, M. Y. Khandelwal and F. Schrödel.
Coaction between Automobiles and Mobile Robots — AmEC 2024; interoperability for affordable last-mile delivery. M. Y. Khandelwal, S. Tendulkar, G. A. Kolbai and F. Schrödel.
Multilayer Environment Model for Outdoor Autonomous Mobile Robot Navigation — 2026 preprint by S. Tendulkar, A. Nannuri, S. Nagdev and F. Schrödel; an ongoing research framework for outdoor navigation.