

HSM ARIES / THE PEOPLE BEHIND THE ROVER
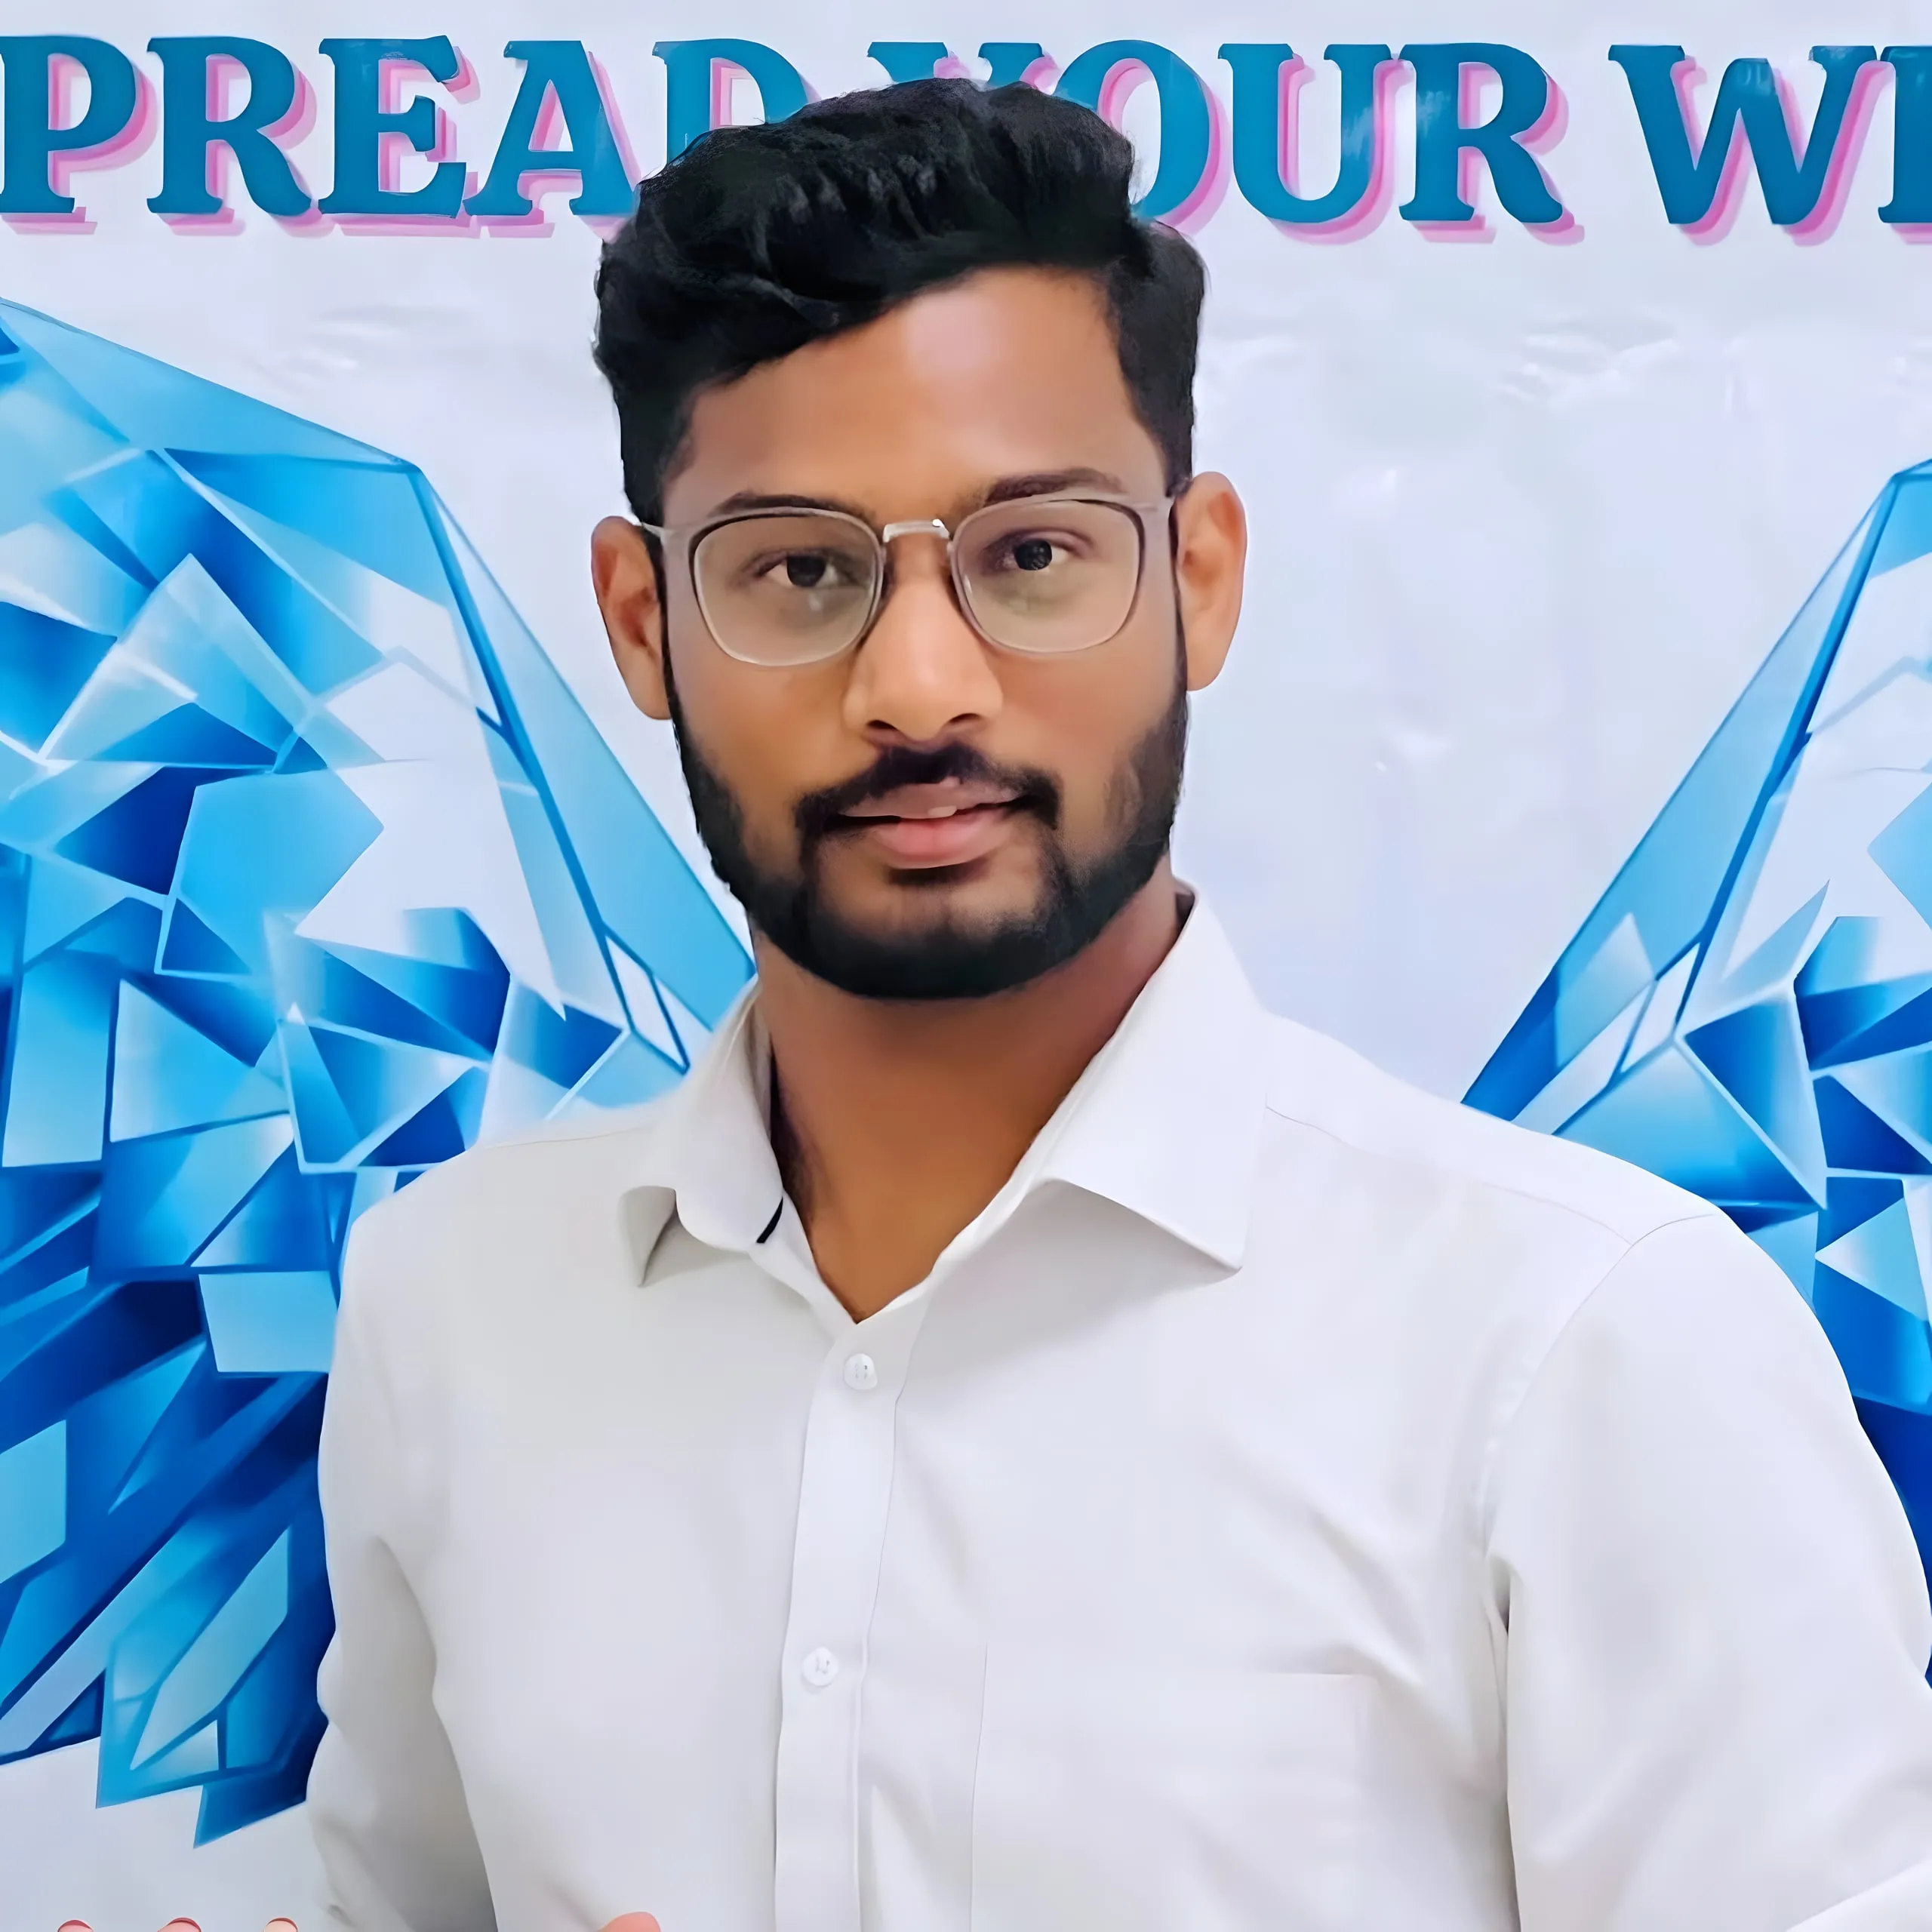
Brahama Teja Naroju
Mechanical Lead & Manipulator Lead
- Mechanical & Drivetrain
- Drill & Manipulator
On the team
Brahama works where a rover drawing becomes a physical machine. As Mechanical and Manipulator Lead, his responsibilities span the chassis, suspension and arm, with particular attention to how parts fit, carry loads and move together. His public project updates describe applying geometric dimensioning and tolerancing directly to Mars-rover components.
He came to his master’s in Mechatronics and Robotics at Hochschule Schmalkalden after three years of professional experience in India. That combination of design study and manufacturing practice informs his approach to the rover. He is a coauthor of the LEAP-One design preprint.
Selected research & projects
LEAP-One: A Mars Rover Designed for Remote Mars Analogue Scientific Exploration and Sampling Missions — 2026 preprint; rover design, scientific sampling and remote operation.