

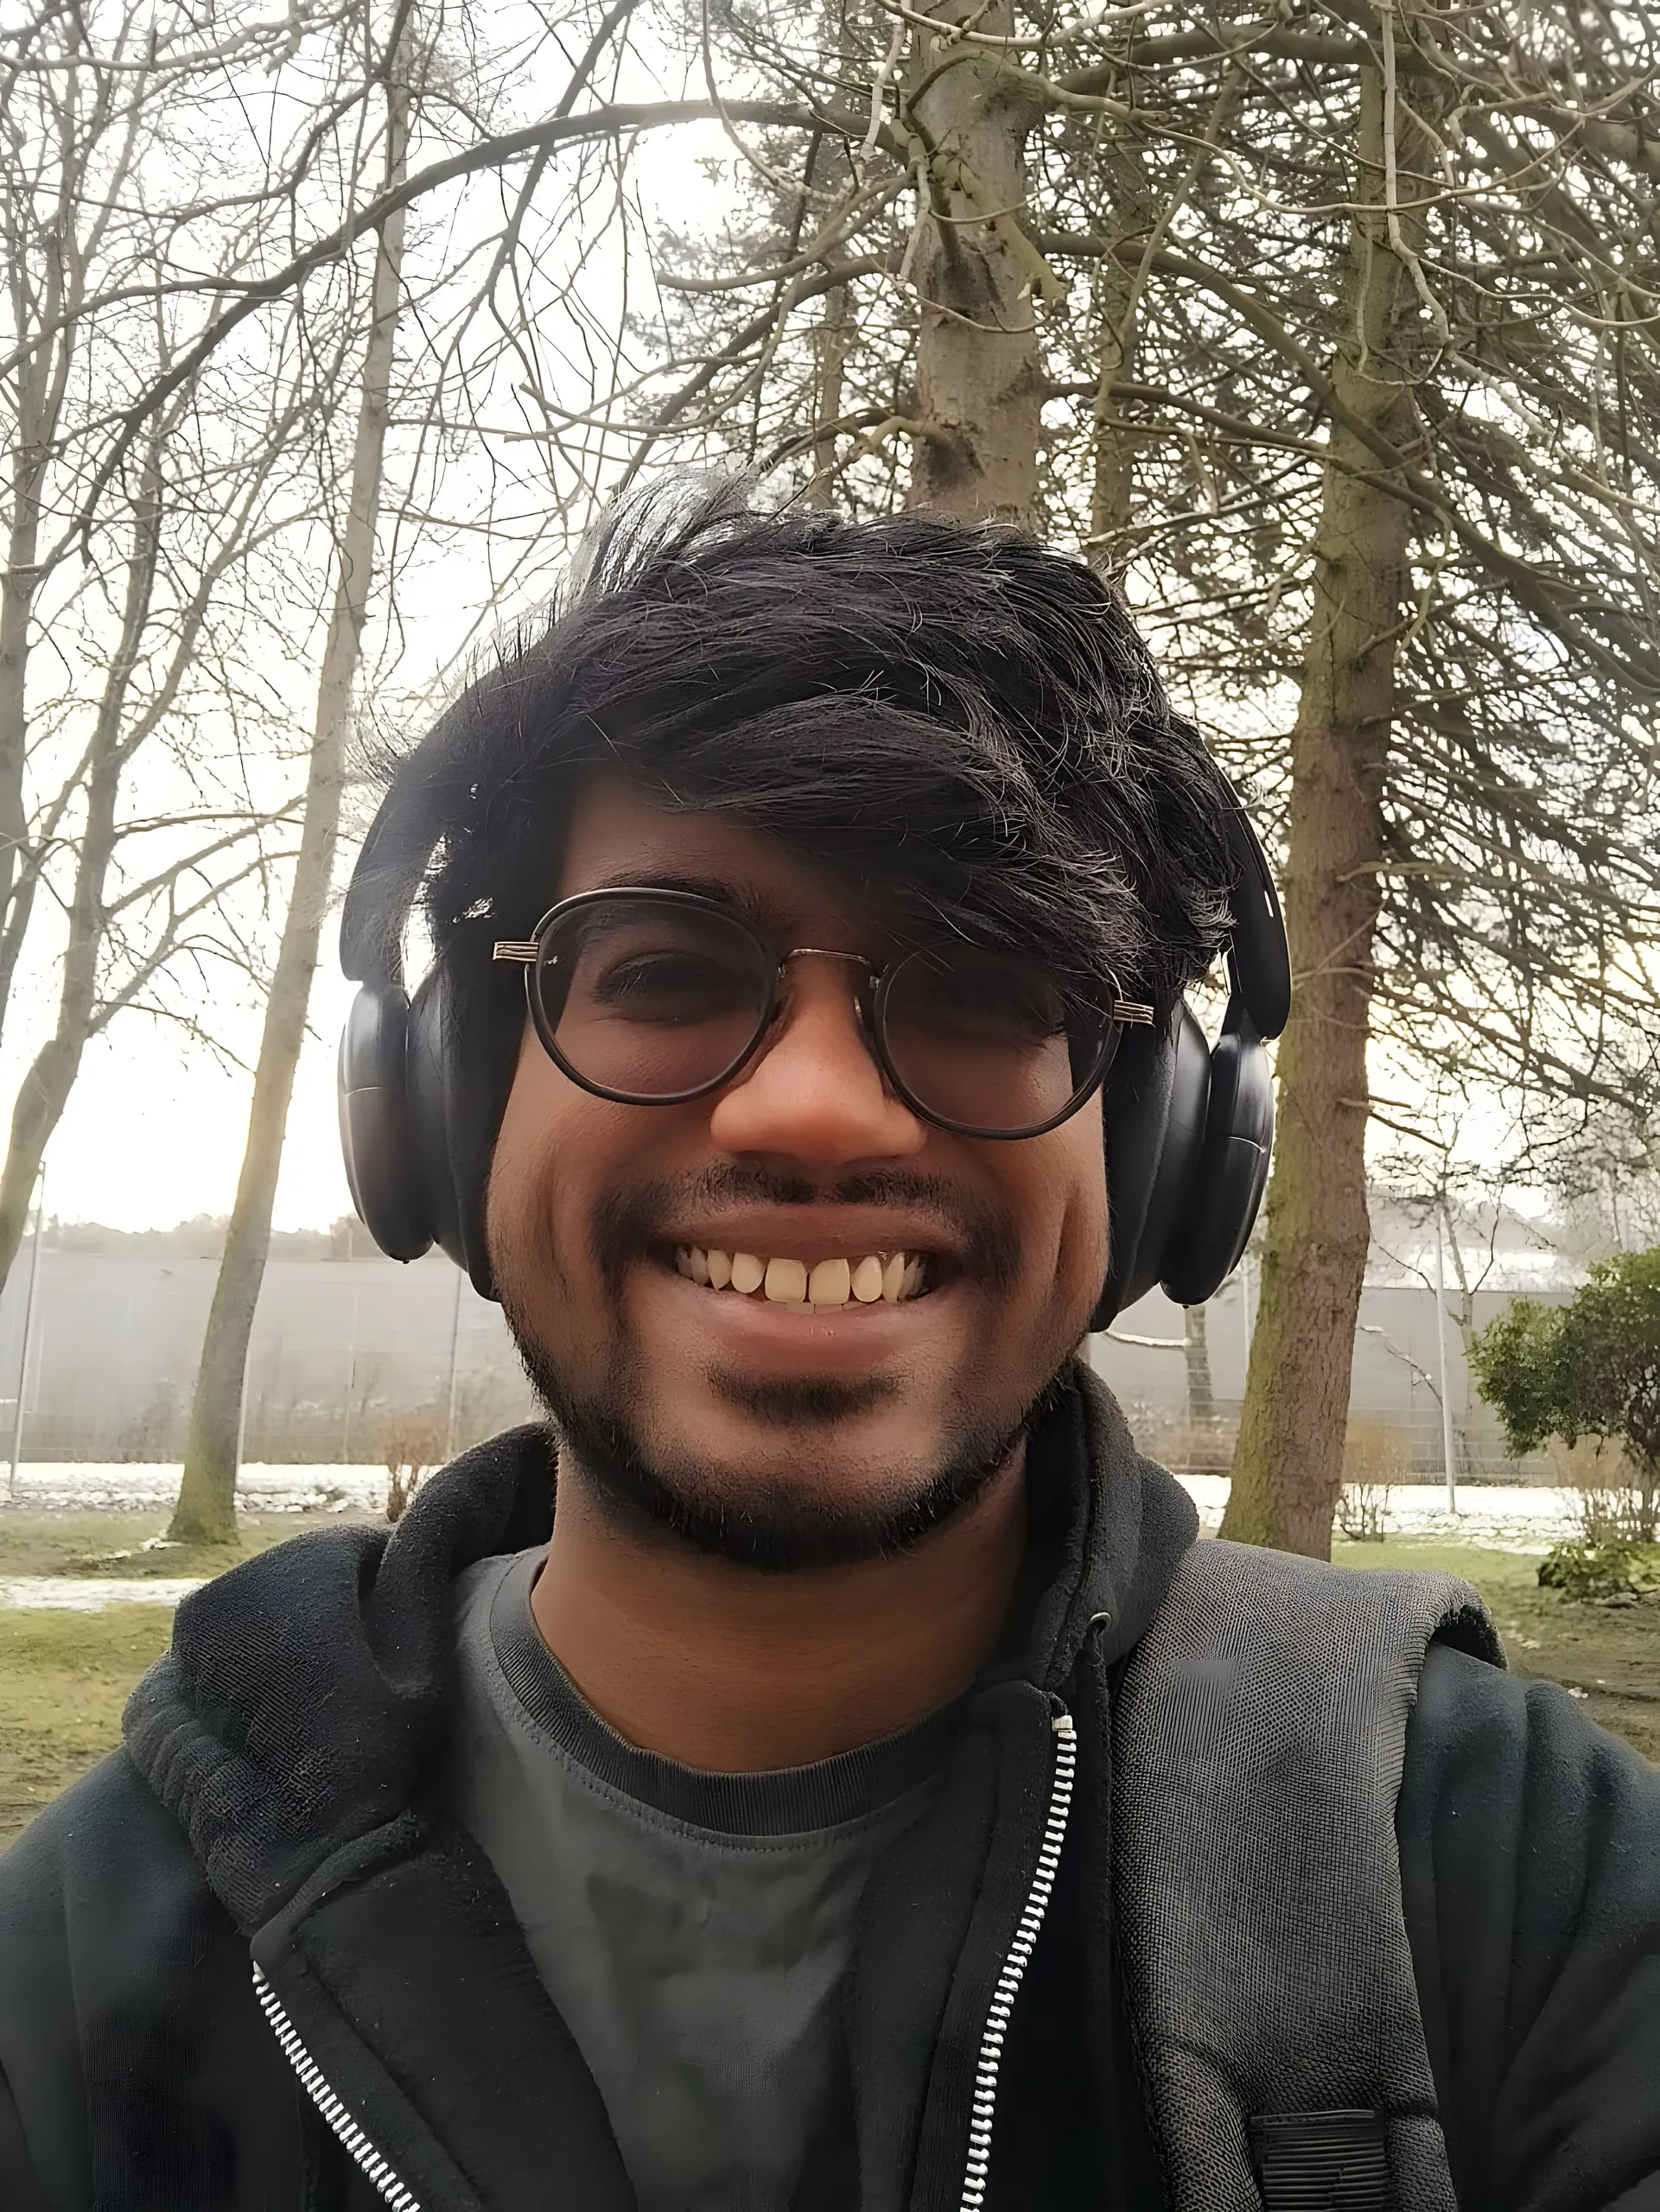
HSM ARIES / THE PEOPLE BEHIND THE ROVER
Danny Sneham
Drill Department Lead
- Drill & Manipulator
On the team
Danny’s part of LEAP-One reaches below the surface. His drill work centres on the auger, sample acquisition and the mechanisms needed to retain material for analysis. It is a practical engineering problem: turning rotary motion into useful penetration while keeping the sampling process compatible with the rest of the rover.
His background includes Hochschule Schmalkalden and experience at Adtran, alongside training in networking and Python. Danny is also a coauthor of the LEAP-One design preprint, contributing to the technical account of a rover built for navigation and scientific sampling.
Selected research & projects
LEAP-One: A Mars Rover Designed for Remote Mars Analogue Scientific Exploration and Sampling Missions — 2026 preprint; rover design, scientific sampling and remote operation.